Seokha Moon
shmoon96[at]korea[dot]ac[dot]kr

Hi!😀 I’m an AI planning researcher in the Autonomous Driving Development Team at KakaoMobility, developing planners for real-vehicle autonomous driving. I received my Ph.D. from Korea University, Vision & AI Lab (Advised by Prof. Jinkyu Kim and Prof. Jungbeom Lee), and my Bachelor’s degree in Computer Science from Yonsei University.
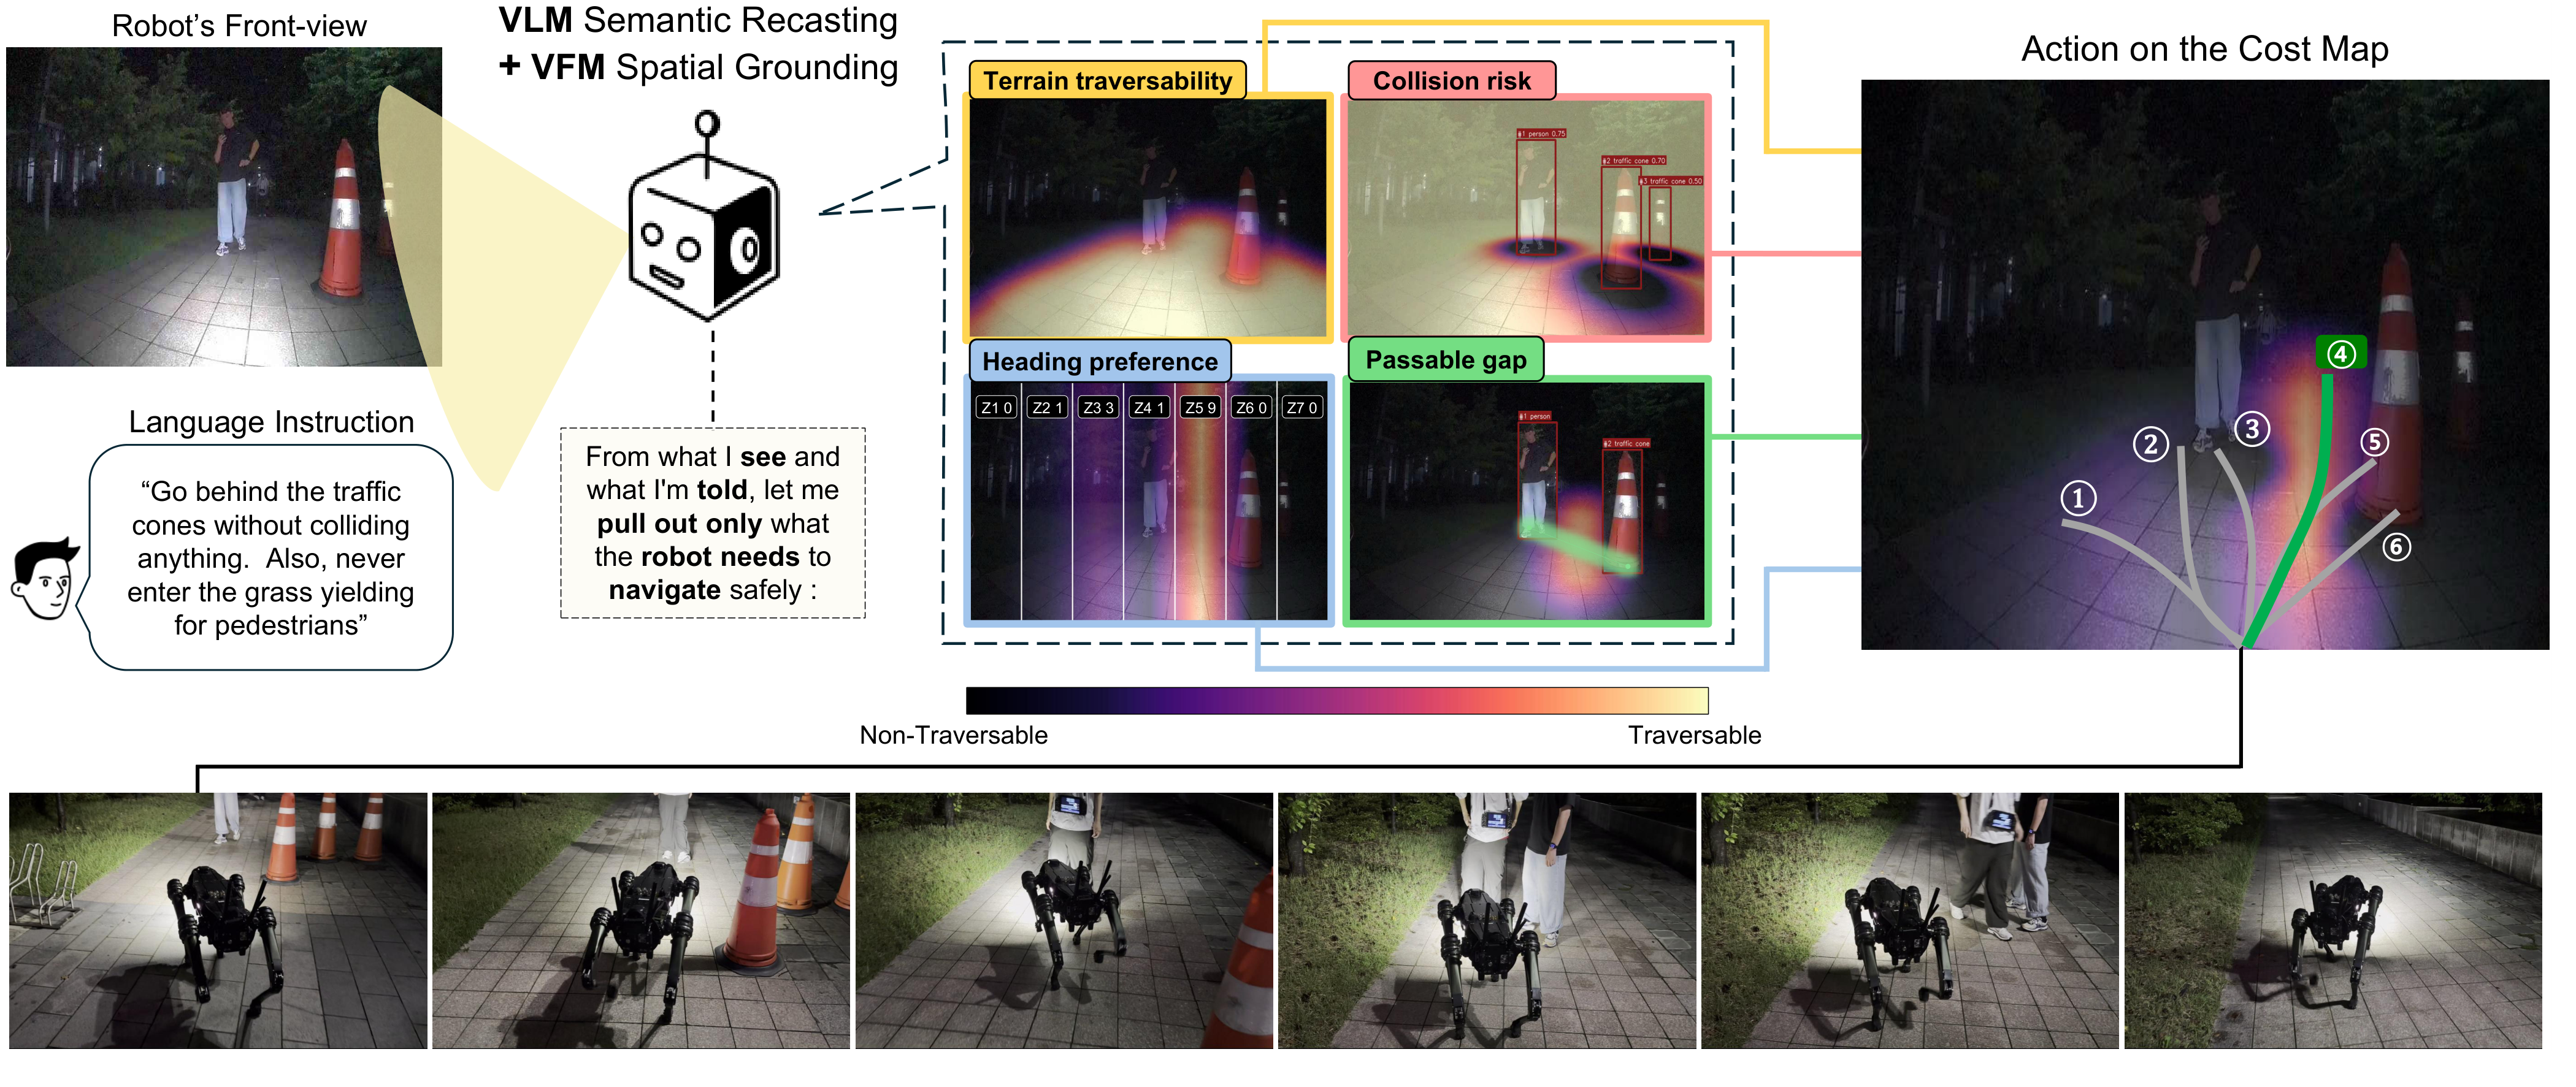
My research interests lie in the field of Autonomous Robots 🤖 and Autonomous Driving 🚗, spanning perception, prediction, and planning. I have worked on camera-based perception for autonomous driving, including 3D detection and occupancy prediction, and on trajectory prediction that models interactions between agents, using vision-driven text guidance as supervision to capture the contextual cues needed to understand each agent’s situation. More recently, I have worked on end-to-end planning with closed-loop reinforcement learning, and on robot navigation that turns the reasoning of vision-language models into actionable cost maps.
Currently, I am interested in reliable closed-loop planning and Vision–Language–Action (VLA) models that integrate perception, reasoning, and decision-making.
news
| Oct 05, 2026 | 🤖 RECAST: Recasting Vision-Language Semantics into an Actionable Cost Map for Robot Navigation is now available with a new project page and arXiv preprint. |
|---|---|
| Aug 31, 2026 | 🎓 I received my Ph.D. from Korea University, Vision & AI Lab! |
| Jun 18, 2026 | 📄✨ Our paper “Streaming Dense Voxel Representations for 3D Occupancy Prediction” (StreamOcc) has been accepted to ECCV 2026! |
| May 18, 2026 | 📄🚗 CaAD: Causality-Aware End-to-End Autonomous Driving via Ego-Centric Joint Scene Modeling is now available with a new project page and arXiv preprint. |
| Apr 06, 2026 | 🚗 I joined the Autonomous Driving Development Team at KakaoMobility as an AI planning researcher. |